

C-Compass
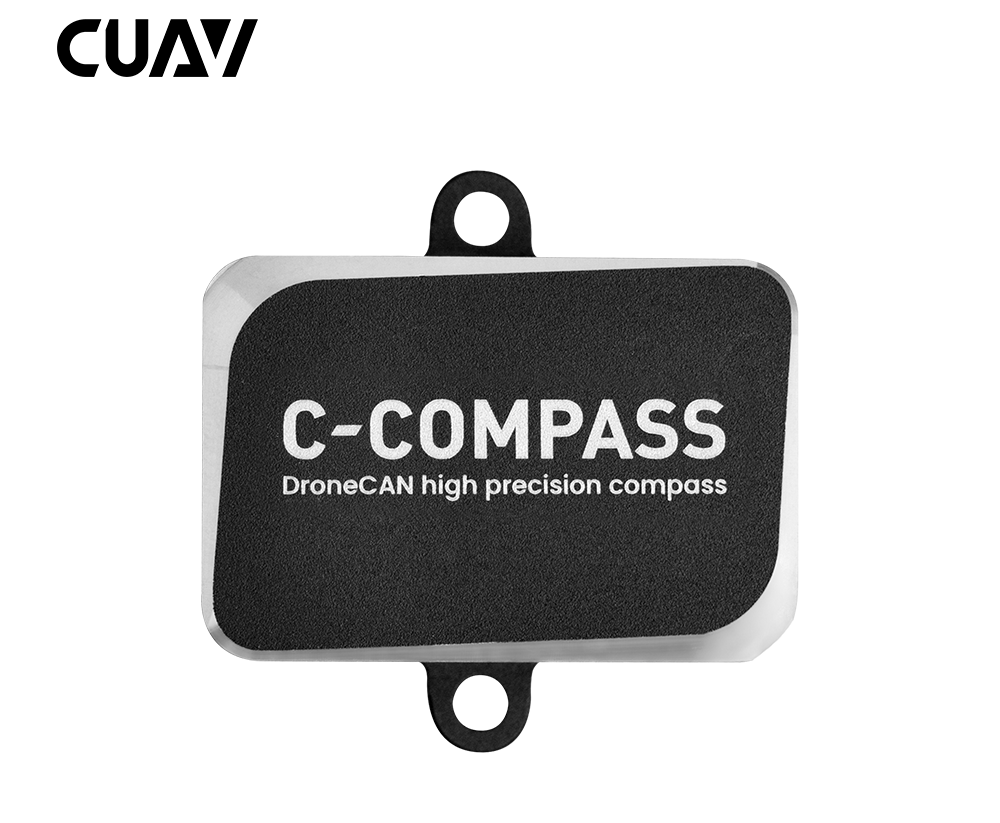
C-Compass is a high-performance industrial anti-interference magnetometer. It integrates a vehicle-grade RM3100 electronic compass and supports the DroneCAN protocol. It is widely used in unmanned systems such as PX4 or ArduPilot as an external compass to eliminate magnetic interference from internal components such as cables, batteries and motors.
Features
- Low noise, low temperature drift, high resolution vehicle-grade RM3100 magnetometer
- Advanced magnetic filtering algorithm effectively eliminates magnetic interference and accurately measures heading
- Self-developed M4C software architecture for rapid customization and development
- DroneCAN bus protocol, supporting open-source platforms such as PX4/ArduPilot
Data sheet
| C-Compass | |
|---|---|
| MCU | STM32F4 |
| Sensor | RM3100 |
| Software architecture | CUAV M4C |
| Protocol | DroneCAN/UAVCAN |
| Communication rate | 2Mb |
| Refresh rate | 80Hz |
| Noise | 15nT |
| Accuracy | 0.25° (effective value) |
| Repetition accuracy | 0.05° |
| Resolution | 0.01° |
| Sensitivity | 13nT |
| Range | -800 μT to +800 μT |
| Controller type | PX4/ArduPilot (CUAV/Pixhawk etc.) |
| Interface | GHR-04V-S |
| Operating voltage | 4.75-5.3V |
| Operating temperature | -20~80℃ |
| Operating humidity | 5%~95% (non-condensing) |
| Casing material | Aluminum alloy |
| Weight | 13g |
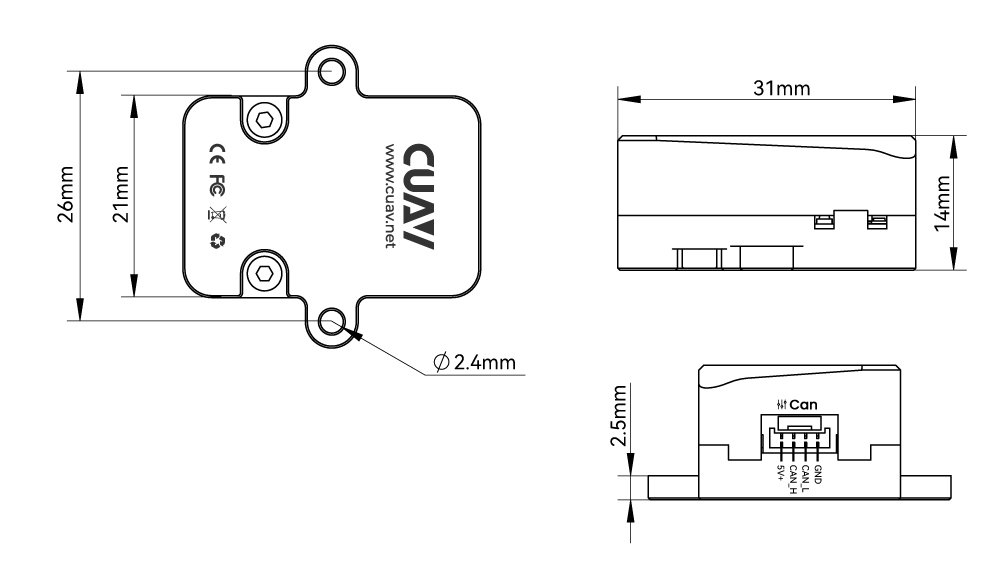
Pinouts
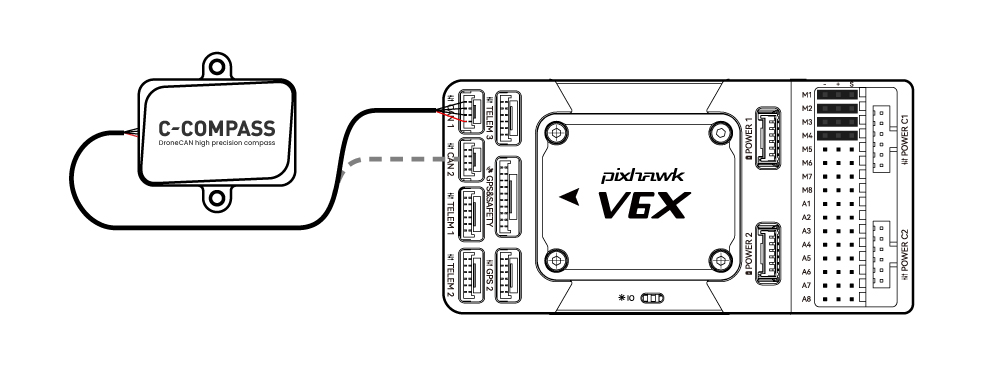
Hardware connection and installation
Tip
Mount the module away from high-power devices such as motors, ESCs and batteries, and secure it to the airframe with M2 screws.
Configuration
Enabling the C-COMPASS magnetometer requires different parameters depending on the controller firmware.