

Parameter meaning
Parameter file
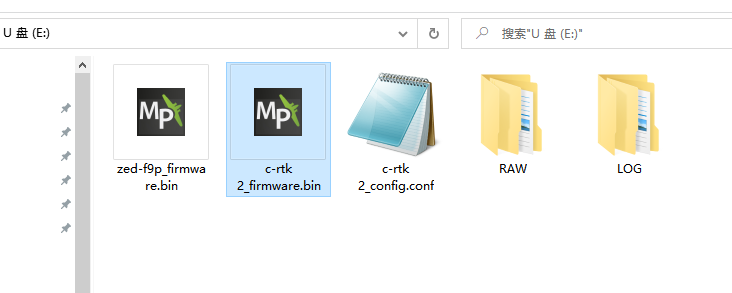
The parameters of C-RTK2 are saved in the TF card directory. You only need to connect C-RTK to the computer, use a text tool to open the "c-rtk 2_config.conf" file, and save it after modification; it will take effect after restarting the device.
Parameter
SYS_MODEset to 1.- System mode. 0:Base, 1:Rover(default)
SYS_UTCset to 0.- Time zone. default:8
SYS_LOGset to 1.- System log enabled. 0:Disable(default), 1:Enable
AHRS_ROTATIONset to 4.- Rotation direction of accelerometer, gyroscope, and compass. (default:4,
ROTATION_YAW_180)
- Rotation direction of accelerometer, gyroscope, and compass. (default:4,
ROTATION_NONEset to 0 .ROTATION_YAW_45set to 1 .ROTATION_YAW_90set to 2 .ROTATION_YAW_135set to 3 .ROTATION_YAW_180set to 4 .ROTATION_YAW_225set to 5 .ROTATION_YAW_270set to 6 .ROTATION_YAW_315set to 7 .ROTATION_ROLL_180set to 8 .ROTATION_ROLL_180_YAW_45set to 9 .ROTATION_ROLL_180_YAW_90set to 10 .ROTATION_ROLL_180_YAW_135set to 11 .ROTATION_PITCH_180set to 12 .ROTATION_ROLL_180_YAW_225set to 13 .ROTATION_ROLL_180_YAW_270set to 14 .ROTATION_ROLL_180_YAW_315set to 15 .ROTATION_ROLL_90set to 16 .ROTATION_ROLL_90_YAW_45set to 17 .ROTATION_ROLL_90_YAW_90set to 18 .ROTATION_ROLL_90_YAW_135set to 19 .ROTATION_ROLL_270set to 20 .ROTATION_ROLL_270_YAW_45set to 21 .ROTATION_ROLL_270_YAW_90set to 22 .ROTATION_ROLL_270_YAW_135set to 23 .ROTATION_PITCH_90set to 24 .ROTATION_PITCH_270set to 25 .ROTATION_PITCH_180_YAW_90set to 26 .ROTATION_PITCH_180_YAW_270set to 27 .ROTATION_ROLL_90_PITCH_90set to 28 .ROTATION_ROLL_180_PITCH_90set to 29 .ROTATION_ROLL_270_PITCH_90set to 30 .ROTATION_ROLL_90_PITCH_180set to 31 .ROTATION_ROLL_270_PITCH_180set to 32 .ROTATION_ROLL_90_PITCH_270set to 33 .ROTATION_ROLL_180_PITCH_270set to 34 .ROTATION_ROLL_270_PITCH_270set to 35 .ROTATION_ROLL_90_PITCH_180_YAW_90set to 36 .ROTATION_ROLL_90_YAW_270set to 37 .ROTATION_ROLL_90_PITCH_68_YAW_293set to 38 .ROTATION_PITCH_315set to 39 .ROTATION_ROLL_90_PITCH_315set to 40 .ROTATION_PITCH_7set to 41 .GPS_UPDATEset to 0.- Perform a GPS firmware update after restarting. 0:Disable(default), 1:Enable
GPS_RATESset to 5.- GPS Refresh rate. range:1~20(1=1Hz)
GPS_GNSSset to 0.- GNSS system configuration. 0:GPS+GLO+GAL+BDS(default), 1:GPS+GLO+GAL, 2:GPS+GAL, 3:GPS+GLO, 4:GPS+BDS
GPS_BASE_MODEset to 1.- Base Receiver mode. 1:Survey-in(default), 2:Fixed Mode
GPS_BASE_MIN_DURset to 60.- Survey-in mode convergence time. range:0~86400(1=1s)
GPS_BASE_ACC_LIMITset to 2.500000.- Survey-in mode convergence accuracy. range:0~9999(1=1m), default:2.5
UAV_ENABLEset to 1.- Shutter input enable. 0:Disable, 1:Enable(default)
UAV_MODEset to 0.- Shutter input mode. 0:Relay(default), 1:PWM
UAV_POLARITYset to 0.- Whether the shutter is open is high or low. 0:Low(default), 1:High
UAV_SERVO_ONset to 1300.- PWM value in microseconds to move servo to when shutter is activated. range:1000~20000(1=1us), default:1300
UAV_SERVO_RATEset to 50.- Servo rate. range:25~400(1=1Hz), default:50
CAM_FEEDBACK_TYPEset to 1.- Camera feedback type. 0:None, 1:Hot Shoe(default)
CAM_FEEDBACK_DURATIONset to 0.- Camera feedback signal duration. range:0~100(1=1ms), default:0
CAM_FEEDBACK_INVERTALset to 1.- Camera feedback interval. range:0~30000(1=1ms), default:1
CAM_DURATIONset to 10.- Duration that shutter is held open. range:0~50(1=100ms), default:10
CAM_POLARITYset to 0.- Whether the shutter is open is high or low. 0:Low(default), 1:High
CAM_STset to 0.- Shutter time compensation. range:-99999~99999(1=1ms), default:0
USB_TYPEset to 3.- USB type. 0:Close, 1:Debug, 3:RTCM(default), 5:GPS
SERIAL1_TYPEset to 1.- Serial1 protocol type. 0:Close, 1:Debug, 3:RTCM(default), 5:GPS
SERIAL1_BAUDset to 115200.- Serial1 baud rate. Default: 115200
BOARD_BARO_ENABLEset to 0.- Barometer enable. 0:Disable(default), 1:Enable
BOARD_COMPASS_ENABLEset to 1.- Compass enable. 0:Disable, 1:Enable(default)