

Mounting the Controller and Accessories
The parts list is under Required parts in the boat guide. The controller goes in first; wiring and parameters follow from where it sits. Mounting a boat takes two steps: fix the controller in the cabin at the correct orientation, then wire the thruster and servo to the matching outputs.
System framework
The arrow on the controller points at the bow. Mount it inside the cabin where it stays dry and away from power leads and the battery, level, as close to the hull's centre of gravity as possible. A boat pitches and rolls, so the controller must sit flat against the hull bottom rather than on a bracket.
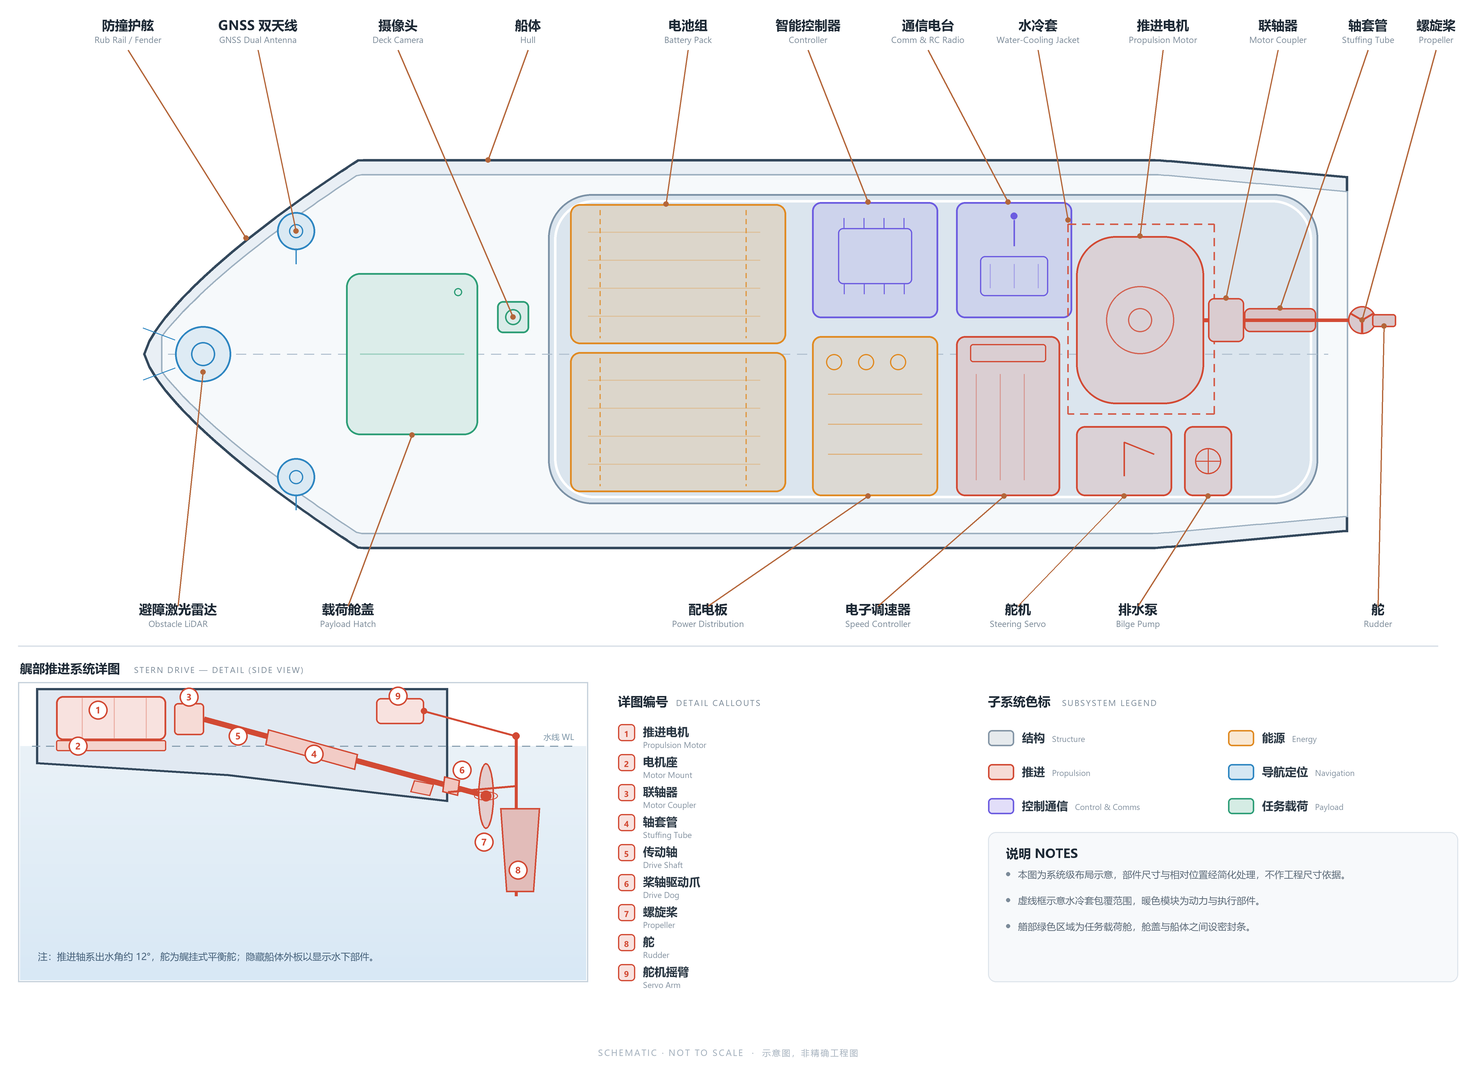
▲ Cabin layout: controller, battery pack, ESC and steering servo in relation to each other; the bow is to the left
Other mounting orientations
When space does not allow the standard orientation, AHRS_ORIENTATION offers more than thirty alternatives. Find Board Orientation in the ground station under Config/Tuning → Advanced Params, and read the sign of each axis from the table below.
| Value | Meaning |
|---|---|
| Roll90 | Board stands 90° to the right; the arrow still points at the bow |
| Pitch90 | Board tips 90° nose-up; the arrow points straight up |
| Yaw90 | Board turns 90° clockwise; the arrow points to starboard |
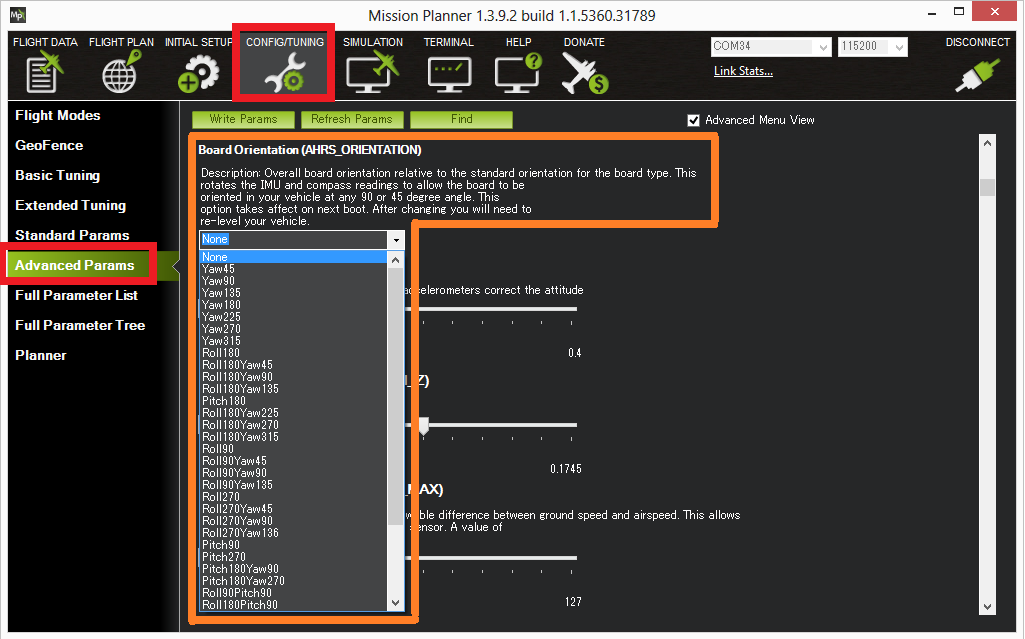
▲ Choose Board Orientation under Advanced Params in the ground station
Set the orientation before calibrating
When the arrow does not point at the bow, set AHRS_ORIENTATION first and calibrate the accelerometer afterwards. Reversing the order gives a wrong attitude calibration.
Thruster, servo and sail winch
A rudder boat uses a steering servo plus an ESC, a twin-screw boat uses two ESCs left and right, and a vector-thrust boat hangs the whole drive unit on the steering servo. Channel numbers and parameters are covered in Thruster and servo connections.
A boat with sails drives its sail winch from its own output; wiring and travel are covered in Sailboat mode.