V5 (Pixhack V5) Controller (Discontinued)
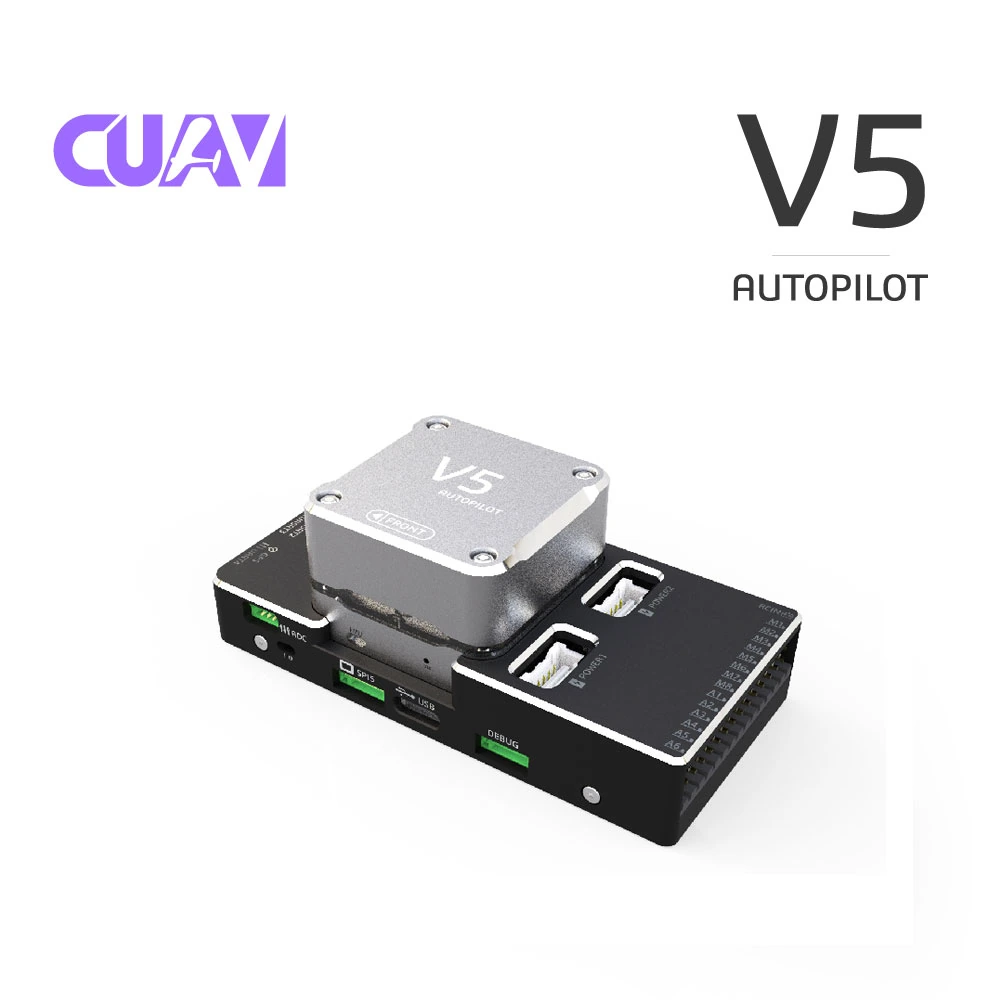
The V5 (previously "Pixhack v5") is a controller designed and made by CUAV. Based on the Pixhawk-project FMUv5 open hardware design, it runs PX4 on NuttX and is fully compatible with PX4 firmware. It is intended primarily for academic and commercial developers. This product has been discontinued and is no longer available.
Hardware Parameters
| Item | Specification |
|---|---|
| FMU Processor | STM32F765 (32 Bit Arm® Cortex®-M7, 216MHz, 2MB Flash, 512KB RAM) |
| IO Processor | STM32F100 (32 Bit Arm® Cortex®-M3, 24MHz, 8KB SRAM) |
| Accelerometer | ICM-20602/ICM-20689/BMI055 |
| Gyroscope | ICM-20602/ICM-20689/BMI055 |
| Compass | IST8310 |
| Barometer | MS5611 |
| UASRT | 2 |
| UART | 3 |
| I2C | 4 |
| PWM Output | IO 8 Standard PWM + 6 Programmable IO |
| RC Signal Input Protocol | PPM/SBUS/DSM/DSM2 |
| RSSI Input | PWM or 3.3 Analog Voltage |
| CAN Standard Bus | 2 |
| Current Voltage Input | 2 |
| Safety Switch | 1 |
| GPS Interface | 1 |
| Debug/F7 SWD Interface | 1 |
| USB Interface | 1 (Type-C) |
| SPI Interface | 1 |
| Operating Voltage | 4.8 ~ 5.4V |
| Power Module Operating Voltage | 10 ~ 58V |
| USB Voltage | 5V±0.25V |
| Servo Input | 0 ~ 36V |
| Operating Temperature | -20 ~ 80℃ |
| Dimensions (L×W×H) | 89 × 42.5 × 33 mm |
| Weight | 90g |
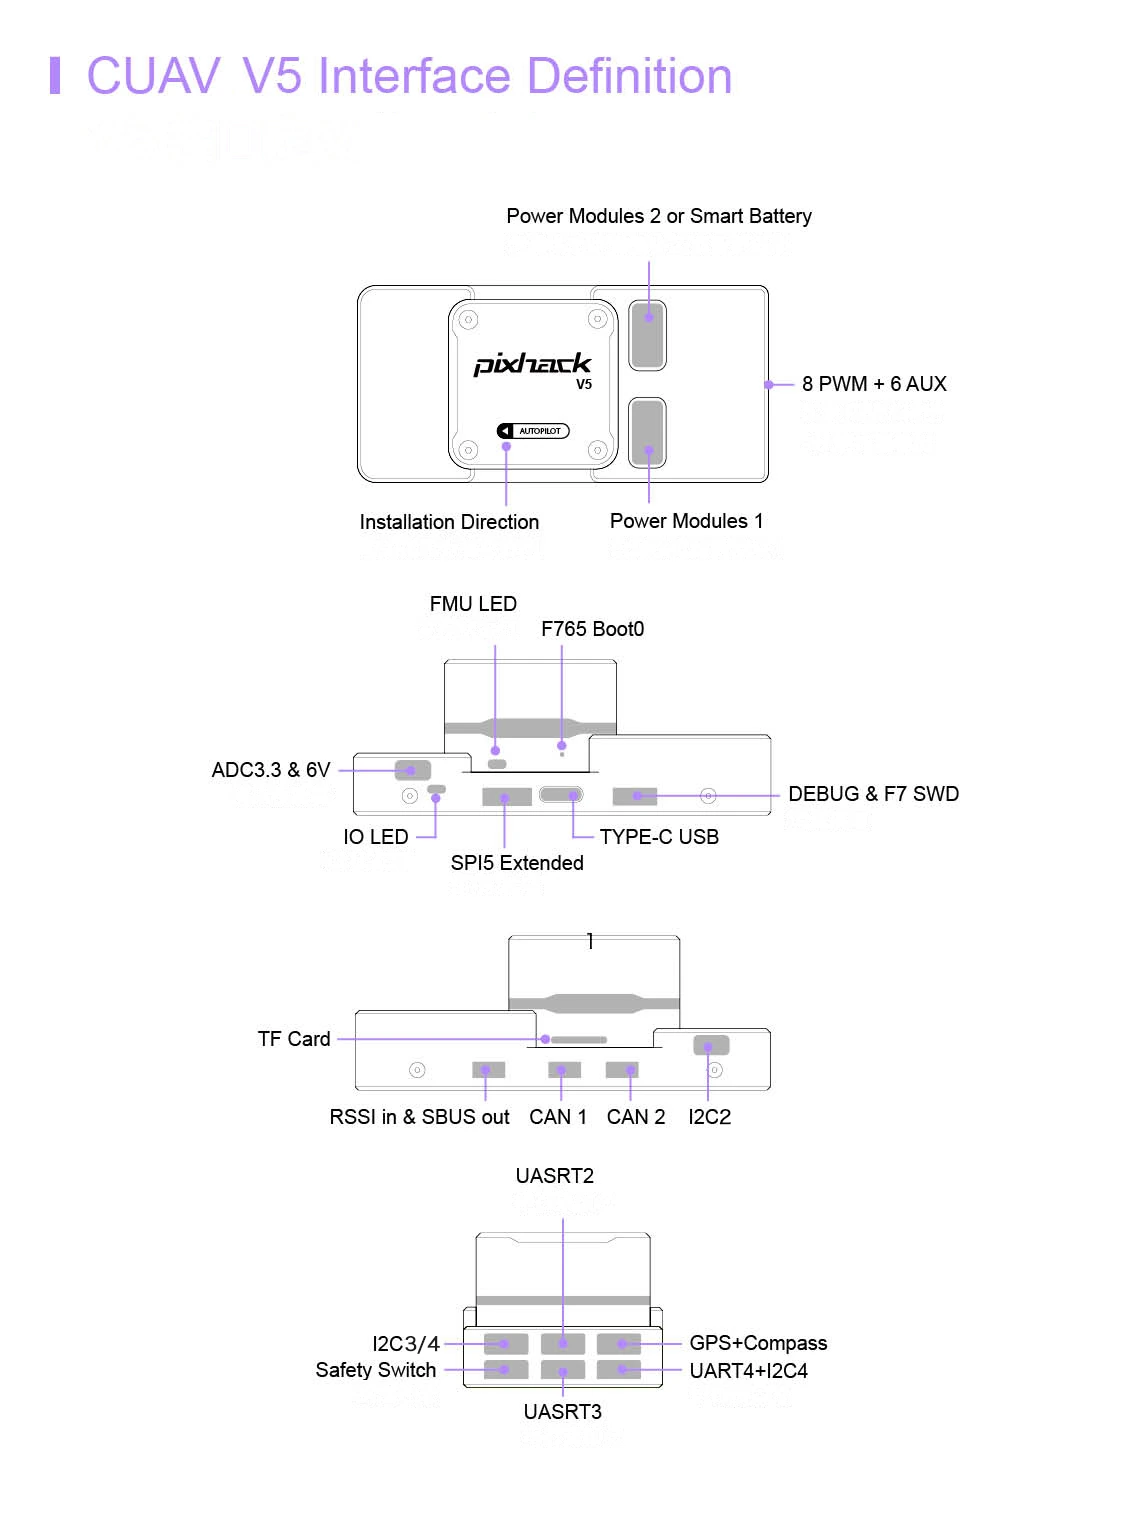
Interface Definition
Warning
The RCIN interface is limited to powering the RC receiver and cannot be connected to any power/load.
Voltage Ratings
The V5 can be triple-redundant on the power supply if three power sources are supplied. The three power rails are POWER1, POWER2 and USB.
Note
The output power rails FMU PWM OUT and I/O PWM OUT (0V to 36V) do not power the controller board (and are not powered by it). You must supply power to one of POWER1, POWER2 or USB or the board will be unpowered.
Under normal operation all power sources are used in this order to power the system:
- POWER1 and POWER2 inputs (4.3V to 5.4V)
- USB input (4.75V to 5.25V)
Building Firmware
Tip
Most users will not need to build this firmware. It is pre-built and automatically installed by QGroundControl when the controller is connected.
To build PX4 firmware for the V5:
make px4_fmu-v5_defaultDebug Port
The PX4 System Console and SWD interface operate on the FMU Debug port. Connect the FTDI cable to the Debug & F7 SWD connector. To access the I/O Debug port, remove the V5 shell. Both ports have standard serial pins and can be connected to a standard FTDI cable (3.3V, but 5V tolerant).
| Pin | Signal |
|---|---|
| 1 | GND |
| 2 | FMU-SWCLK |
| 3 | FMU-SWDIO |
| 4 | UART7_RX |
| 5 | UART7_TX |
| 6 | VCC |
Serial Port Mapping
| UART | Device | Port |
|---|---|---|
| UART1 | GPS | /dev/ttyS0 |
| USART2 | TELEM1 (flow control) | /dev/ttyS1 |
| USART3 | TELEM2 (flow control) | /dev/ttyS2 |
| UART4 | TELEM4 | /dev/ttyS3 |
| USART6 | TX is RC input from SBUS_RC connector | /dev/ttyS4 |
| UART7 | Debug Console | /dev/ttyS5 |
| UART8 | PX4IO | /dev/ttyS6 |
Supported Airframes
- Plane
- Helicopter
- Copter
- VTOL
- Unmanned Boat
- Unmanned Vehicle